Foveated Vision
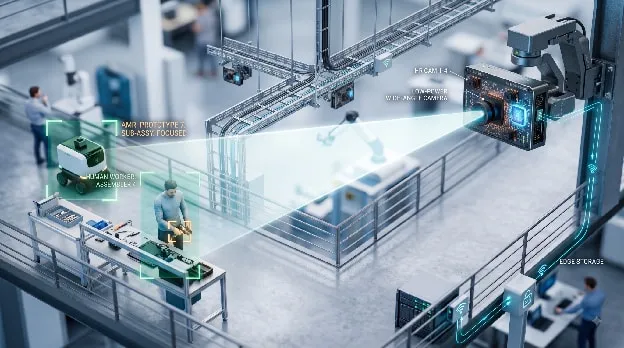
This project develops an energy-efficient vision system for always-on edge applications. Instead of continuously running multiple high-resolution cameras, a low-power camera continuously monitors the wider scene and identifies where motion or important activity is occurring. The system then selectively activates only the high-resolution cameras needed to capture those regions in greater detail. An adaptive controller evaluates the expected visual information gain against the additional energy and computational cost before activating each camera. The captured high-resolution regions are then combined with the wider low-resolution view to create a detailed representation of the scene. By focusing camera and computing resources only where they are needed, the system reduces unnecessary power consumption and processing while maintaining useful visual information. This approach is suitable for applications such as robotics, smart surveillance, drones, and other battery-powered edge vision systems that require continuous environmental awareness and efficient real-time processing.